Teaching
Instructor
EE 543 - Robot Manipulation, University of Washington, Winter 2023
EE 543 focuses on the analytical and computational methods of robot arm manipulation. The following topics is covered in this course: coordinate transformations & rigid body motions, forward & inverse kinematics, differential kinematics & manipulator dynamics, trajectory generation, motion planning, and teleoperation.
Open-sourced materials: slides (copyright: Haonan Peng), textbook (copyright: Prof. Blake Hannaford)
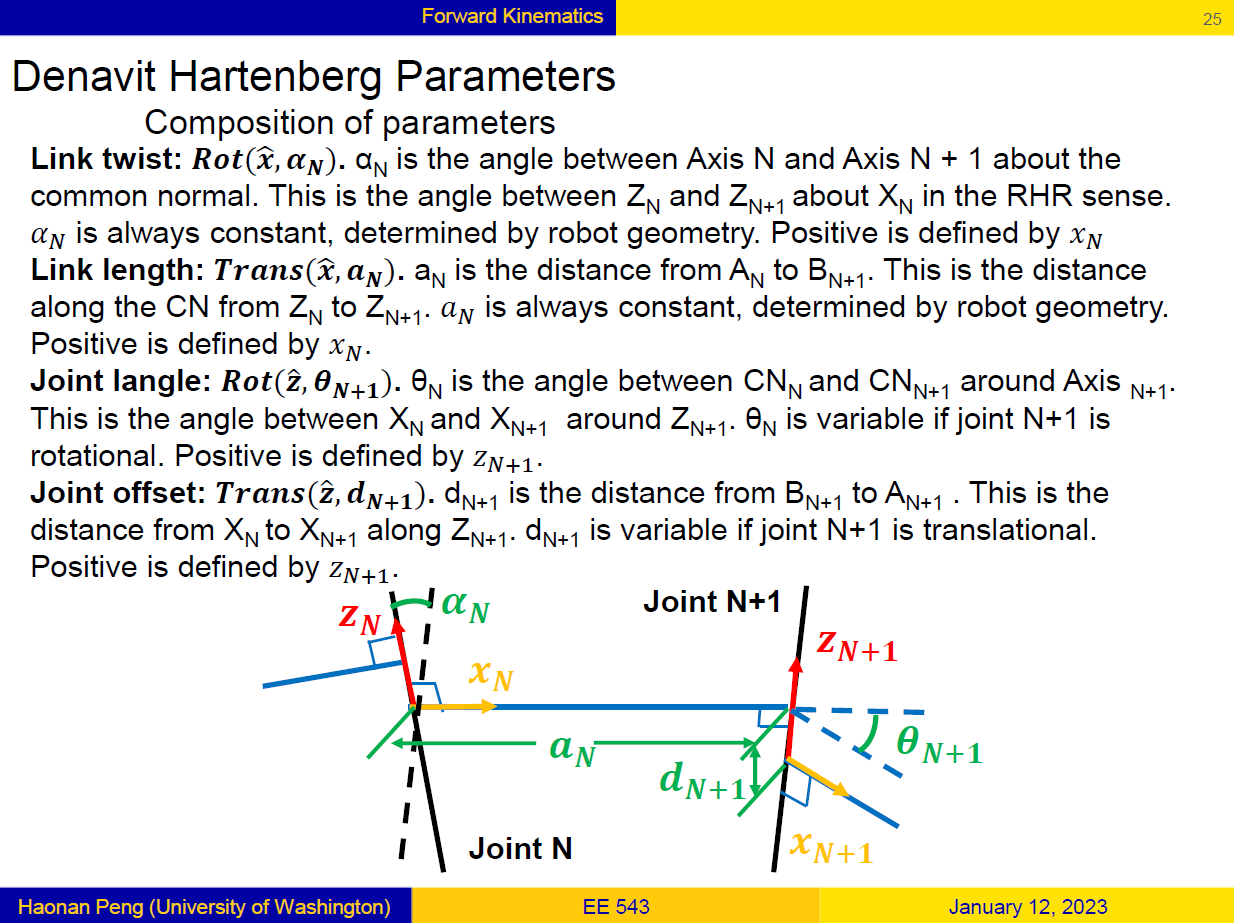
Fig.1. Example slides
Project Manual Robot Manipulation
This is the associated project for Robot Manipulation. In this project, students will be guided to build a robot arm with 3-4 joints from scratch. Based on EE 543 course materials, students can learn and implement:
- Design and assemble robot arm from provided servo motors, arm links, power supply, and so on
- Assign frames for each joint and derive proximal DH parameters
- Apply forward kinematics and analyze the workspace of the robot
- Solve inverse kinematics and achieve intuitive end-effector position control in Cartesian space
- Derive the Jacobian matrix and achieve end-effector velocity control, and analyze the singularity (optional).
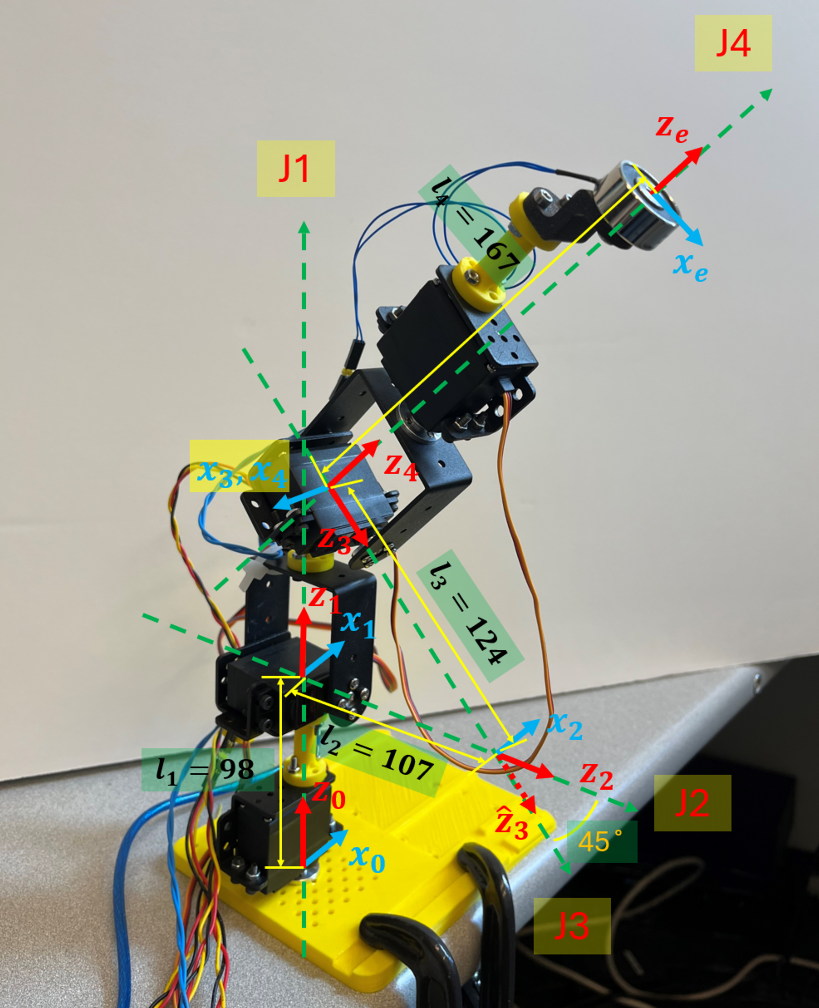
Fig.2. Example robot arm of the Robot Manipulation project
Course Developer and Teaching Assistant
Techin 512 - Introduction To Sensors And Circuits, University of Washington, 2020-2024
Students will gain the background and techniques needed to connect digital systems to the physical world by learning the fundamentals of integrating sensors and microcontrollers. Students will also gain experience in the general process of sensor selection and designing hardware systems.
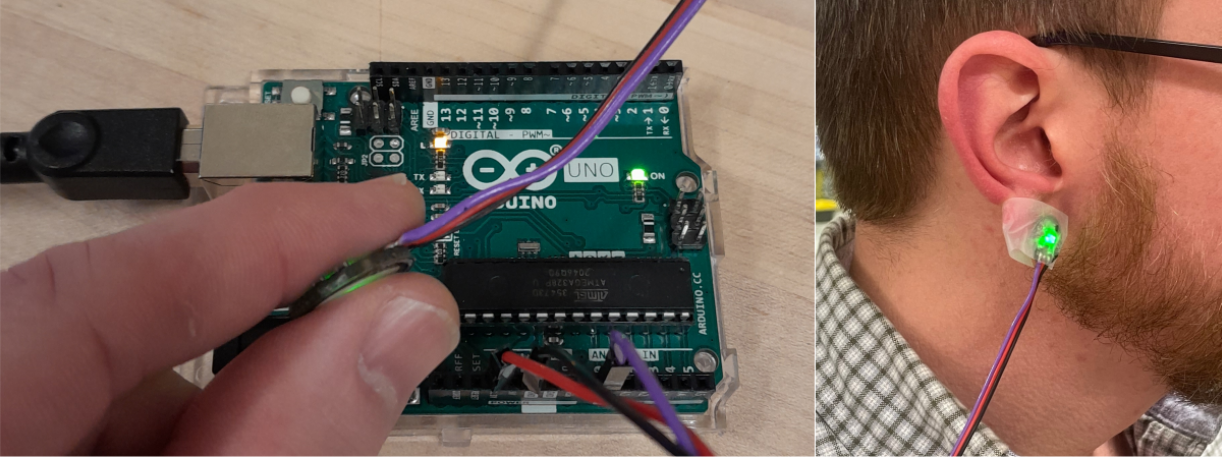
Fig.3. PPG Sensor Lab
Techin 517 – Robotics Lab 2 2023-2024
Applied work with robot arms and graspers, often in combination with sensors such as cameras, to perform manipulation and grasping tasks. Laboratory consists of advanced robot manipulators, configured for a series of tasks of increasing difficulty. A matching simulation environment allows student-written software to be initially partially debugged before engaging the actual robots.
Result video of the project
Techin 514 – Hardware/Software Lab 1, Winter 2022
Students given a real-world experience in developing hardware/software systems to gather an understanding of the entire lifecycle of building such a system from concept through requirements and through implementation, and finally testing.
Techin 515 – Hardware/Software Lab 2, University of Washington, Spring 2024
Builds on the foundation of TECHIN 514 and incorporates physical fabrication into course objectives. Students continue prototyping hardware/software systems, with the added complexity of signal processing, networking, cloud interfaces, and web-based user interfaces.
EE 241 - Programming For Signal And Information Processing Applications, University of Washington, Winter 2024
Introduction to programming for signal and information processing. Basic syntax and data types. Packages for data manipulation and visualization. Handling a variety of data formats.
EE 447 - Control System Analysis I, University of Washington, 2020-2021
Linear Servomechanism theory and design principles. Pole-zero analysis, stability of feedback systems by root locus and real-frequency response methods. Design methods of Bode and Nichols. Introduction to advanced topics in automatic control theory, state variable methods.